Robotics / news brief
ETH researchers show one contact planner across humanoid mobility skills
- Event
- Published
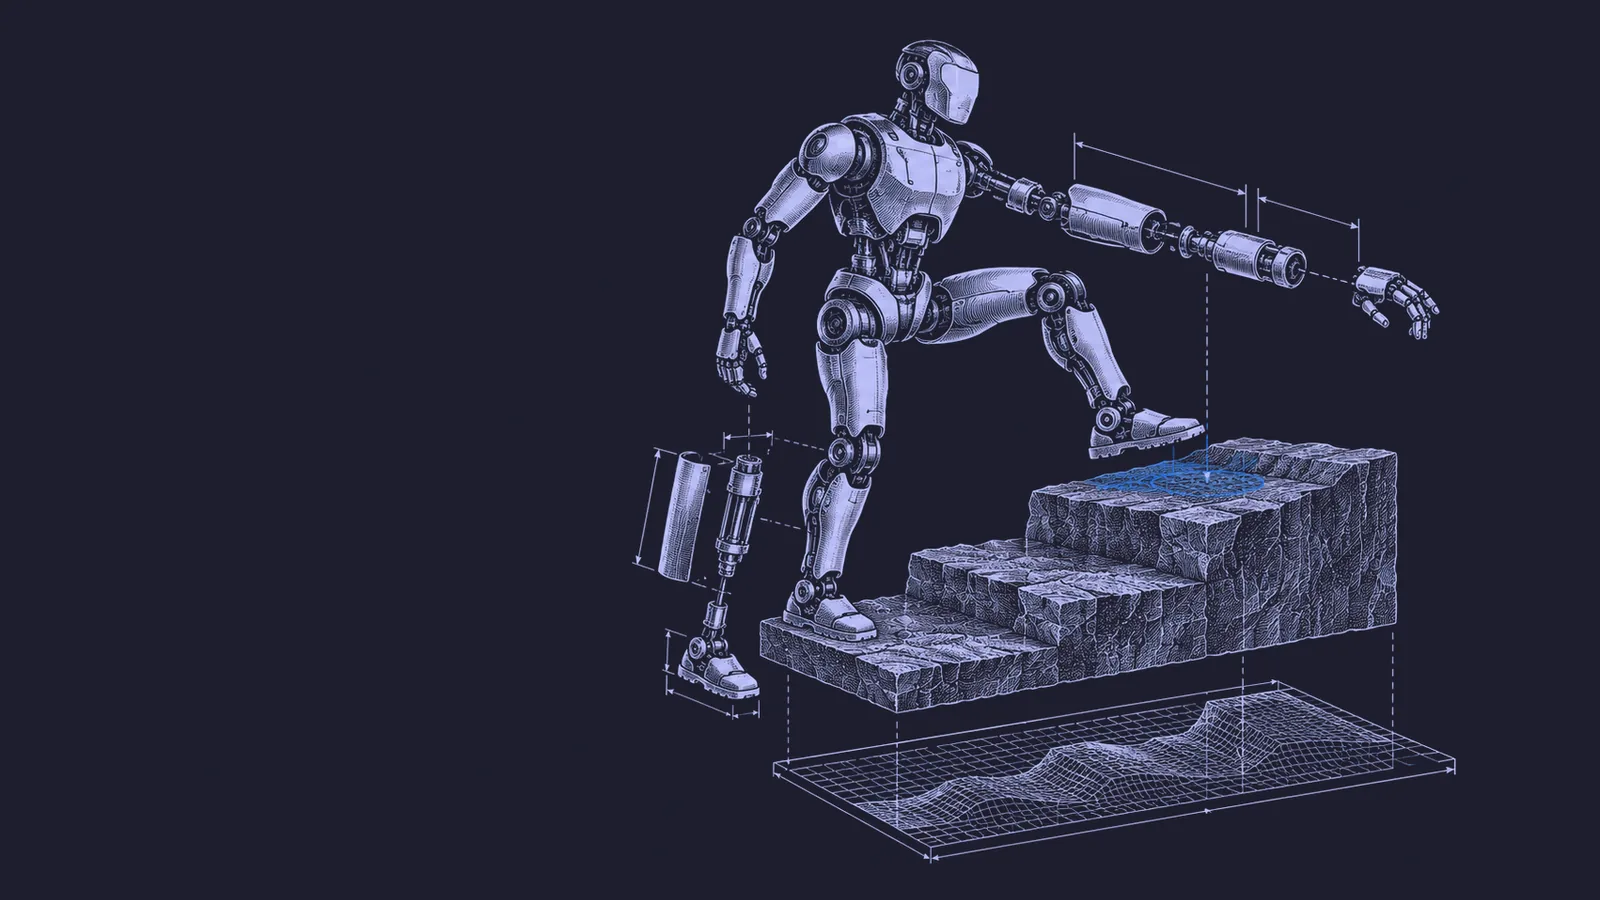
ETH Zurich-led researchers released Humanoid Mobility via Attention-based Contacts, combining a generalist contact planner, tracker and neural map. The project says 13.2 minutes of human motion teach contact patterns and that one policy plans contacts from LiDAR height maps and a goal; code and an independent evaluation are not yet available.
Why it matters
A shared planner across feet, hands, knees, elbows and pelvis could reduce skill-specific engineering for contact-rich humanoid mobility if the results generalize beyond the authors' demonstrations.
Sources
- Humanoid Mobility via Attention-based Contacts (external site)ETH Zurich Robotic Systems Lab · primary source ·
- Humanoid mobility via a generalist contact planner and tracker (external site)ETH Zurich Robotic Systems Lab · coverage ·
Single source: Primary research release with a paper and direct author announcement; no independent evaluation or coverage was found in this narrow collection window.